| ★ | 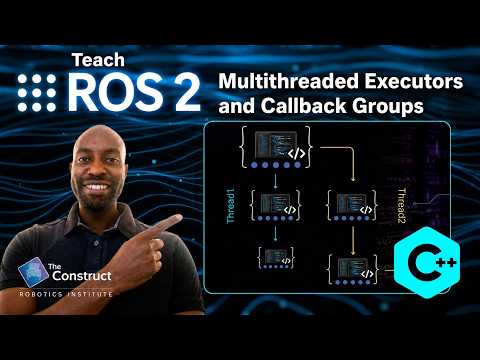 How to Teach ROS 2 Multithreaded Executors and Callback Groups | The Construct Robotics Institute @theconstruct | 901 | España | |
| 17 |  From Chat to Action: Understanding the OpenClaw System Architecture | Analytics Vidhya @analyticsvidhya | — | India | 86 |
| 18 |  OpenClaw Full Tutorial for Beginners – How to Set Up and Use OpenClaw (ClawdBot / MoltBot) | freeCodeCamp.org @freecodecamp | 491.6K | Estados Unidos | 86 |
| 16 |  Why Robotics Still Isn't Solved - But Could Be Soon | YC Paper Club | | 111.2K | Estados Unidos | 86 |
| 13 |  Multithreading in Python | | 13.3K | India | 87 |
| 4 |  How to Teach LiDAR-Based Obstacle Detection Zones in ROS 2 (C++) | The Construct Robotics Institute @theconstruct | 3.2K | España | 90 |
| 5 |  Sensor Fusion in ROS 2 | ROS Developers Open Class #209 | The Construct Robotics Institute @theconstruct | 3.0K | España | 89 |
| 15 |  Python + Agentes: Orquestando workflows multi-agent avanzados | Microsoft Reactor @microsoftreactor | 1.6K | — | 86 |
| 6 | 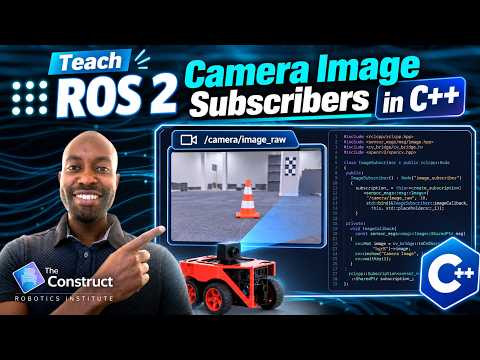 For robotics teachers: ROS2 Camera Image Subscriber in C++ | Open Class #8 | The Construct Robotics Institute @theconstruct | 1.2K | España | 89 |
| 1 |  For robotics teachers: ROS2 Improved Obstacle Avoidance with Executors (C++) | Open Class #4 | The Construct Robotics Institute @theconstruct | 773 | España | 94 |
| 3 |  For robotics teachers: How to Implement ROS 2 Obstacle Avoidance (C++) | Open Class #3 | The Construct Robotics Institute @theconstruct | 756 | España | 90 |
| 9 |  How to Teach ROS 2 Manual Mapping: Teleoperated SLAM with Cartographer | The Construct Robotics Institute @theconstruct | 753 | España | 88 |
| 10 | 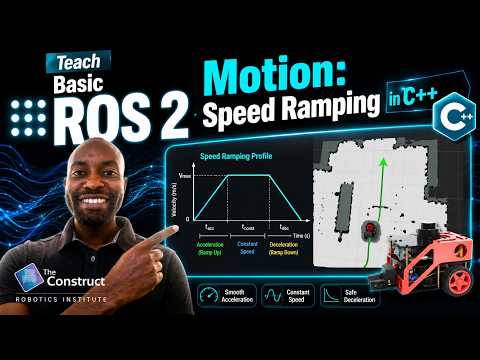 For robotics teachers: ROS2 Basic Motion — Speed Ramping in C++ | #12 | The Construct Robotics Institute @theconstruct | 734 | España | 88 |
| 2 |  For robotics teachers: ROS2 Services in C++: Request-Response Communication for Robot Monitoring #6 | The Construct Robotics Institute @theconstruct | 724 | España | 91 |
| 12 |  For robotics teachers: ROS2 AMCL Localization — Particle Filter on a Known Map | Open Class #11 | The Construct Robotics Institute @theconstruct | 578 | España | 87 |
| 7 |  For robotics teachers: ROS2 Basic Motion — Square Path in C++ | Open Class #9 | The Construct Robotics Institute @theconstruct | 489 | España | 89 |
| 8 |  How to Teach Building a ROS 2 Velocity Command Publisher in C++ | The Construct Robotics Institute @theconstruct | 278 | España | 89 |
| 14 |  How Google Turned Multiple Robots Into One Super Brain #gemini #hive | GenerativeAI @generativeai72 | 115 | Estados Unidos | 87 |
| 19 |  Tinkercad : démo rotation d'un pignon assemblé sur un moteur continu | Laurent Chastain @laurentchastain | 77 | Francia | 86 |
| 20 |  Single Sensor Robots Are Dead | Conversations at the Edge S2E11 | NXP Developer Zone @nxpdeveloperzone | 39 | Países Bajos | 86 |
| 11 |  Detección de Objetos con LIDAR usando DBSCAN en ROS2 | Conducción Autónoma | Iron Makers MX @ironmakers_mx | 7 | México | 88 |